Challenge
Electroadhesion ready for industry
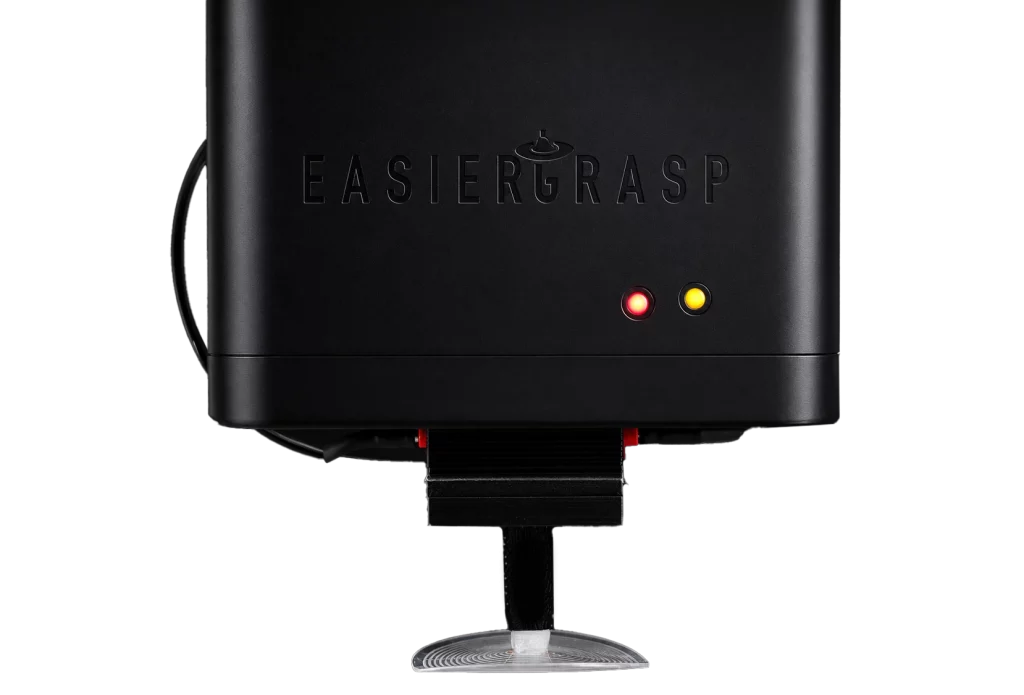
Despite its potential, electroadhesion still faces challenges in achieving widespread industrial adoption, as current solutions are mainly effective for lightweight, flat objects rather than complex industrial applications. The EasierGrasp project aims to overcome these limitations by transforming OmniGrasp’s electroadhesive technology—which enables the adaptive and delicate gripping of objects with different shapes, surfaces and levels of fragility—from a promising prototype into a robust, industrial-ready solution.
Through validation in industrial pilot applications in sectors such as packaging, automotive and logistics, the project will demonstrate the reliability, speed and versatility required for real-world automation. The results, combined with the business and industrialisation strategy, will support the future market adoption of electroadhesive gripping technology across multiple application fields.